EN
Custom Plywood Pallets: From Prototype Validation to Mass Production and Delivery
2026/10/09
Explore PackCube’s custom plywood pallet project, from design and prototypes to customer on-site validation, mass production after approval, and shipment.
2026/09/19
Start with the transport instructions for the exact robot and configuration. Identify its permitted transport position and confirm which interfaces are authorized for lifting, attachment to a transport base, and restraint during shipment. A lifting point alone is not evidence that the same point is approved for transport restraint.
The following review framework helps prepare a packaging brief. It does not specify rigging, fasteners, tightening torques, restraint loads or a shipping procedure for an individual robot.
Record the robot model, serial number, controller model, fitted tooling, cable dress and other options. Identify the applicable document number and revision, including any instructions supplied for the configured assembly. A manual for a similar robot or a controller cannot fill a missing instruction for the actual manipulator.
For example, ABB's IRB 14050 manual, revision S, connects stability with transport posture and securing the robot before repositioning. It also notes that options can affect the position used at delivery. A picture of a standard robot therefore does not establish the required posture for every configuration. ABB, section 2.2.5, pp. 50–51.
Use separate entries in the packaging brief:
| Interface | Question to resolve | Evidence to request |
|---|---|---|
| Lifting or manual handling | How is this configuration permitted to be lifted or carried? | Applicable handling instructions and identified contact or attachment locations |
| Robot to transport base | Where may transport loads enter the equipment? | Transport-specific mounting or restraint instructions, or manufacturer technical confirmation |
| Complete package to vehicle or container | How will the assembled shipment be restrained? | A shipment-specific securing arrangement reviewed against the package and logistics conditions |
Do not treat an accessible arm, cover, connector, cable or end effector as a restraint location without evidence for that use. Equally, a manufacturer-authorized handling contact has a defined purpose; it should not become an assumed tie-down point.
ABB's same manual separates manual handling in section 2.3.1 from installation on a workbench in section 2.3.2. Our review conclusion is that those instructions do not, by themselves, validate a transport-base design or vehicle restraint arrangement. ABB, pp. 53–56.
KUKA's Sunrise Cabinet Med instructions, version V5, distinguish the controller from the LBR Med manipulator and refer readers to the separate robot instructions. The controller's own transport section describes its handling methods. These passages do not establish restraint points for other KUKA robots. KUKA, sections 1.1, 3.8.3 and 6, pp. 7, 38–39 and 71.
For the packaging brief, list the manipulator, controller, pendant, gripper, cables and loose accessories individually. Ask which travel together, which require separate protection, and which supplier instructions apply. Record any proposed change to the delivered configuration for technical review.
The following are proposed review inputs, not a manufacturer-approved test procedure:
Document review, a fit check and an inspection provide different evidence. None alone demonstrates performance throughout a shipment. Any handling trial or transport test needs a project-specific procedure and competent review. Keep the approved drawing revision, packing photos, component list, inspection results and unresolved exceptions together.
Confirm them against the manufacturer's instructions for the exact equipment. If a proposed use is undocumented, seek manufacturer technical confirmation before treating it as permitted. The distinction between ABB's handling and installation sections supports reviewing each use separately; it does not supply a universal restraint drawing. ABB, sections 2.3.1–2.3.2.
Mark it as unknown. Request configuration-specific information from the equipment manufacturer or responsible system integrator, and leave decisions that depend on it unresolved. This is a review recommendation informed by ABB's model-specific stability warning, not a method for estimating the center of gravity from a photograph. ABB, section 2.2.5.
First match it to the applicable equipment instructions; then have the responsible engineers define the necessary checks, test conditions and acceptance criteria for the actual shipment. KUKA's separation of robot and controller instructions illustrates why a single component manual cannot validate the complete package. This article supplies no test pass or transport approval. KUKA, sections 1.1 and 3.8.3.
PackCube is an integrated industrial packaging systems company. For an initial packaging engineering discussion, prepare the robot model and configuration, equipment and packed dimensions and masses, documented transport posture, permitted restraint interfaces, separate lifting instructions, accessories, destination and transport mode. Start through the Engineering Requirements Form below the News section on the PackCube homepage. Use the form for initial contact; robot-specific information and technical documents can be discussed during follow-up.
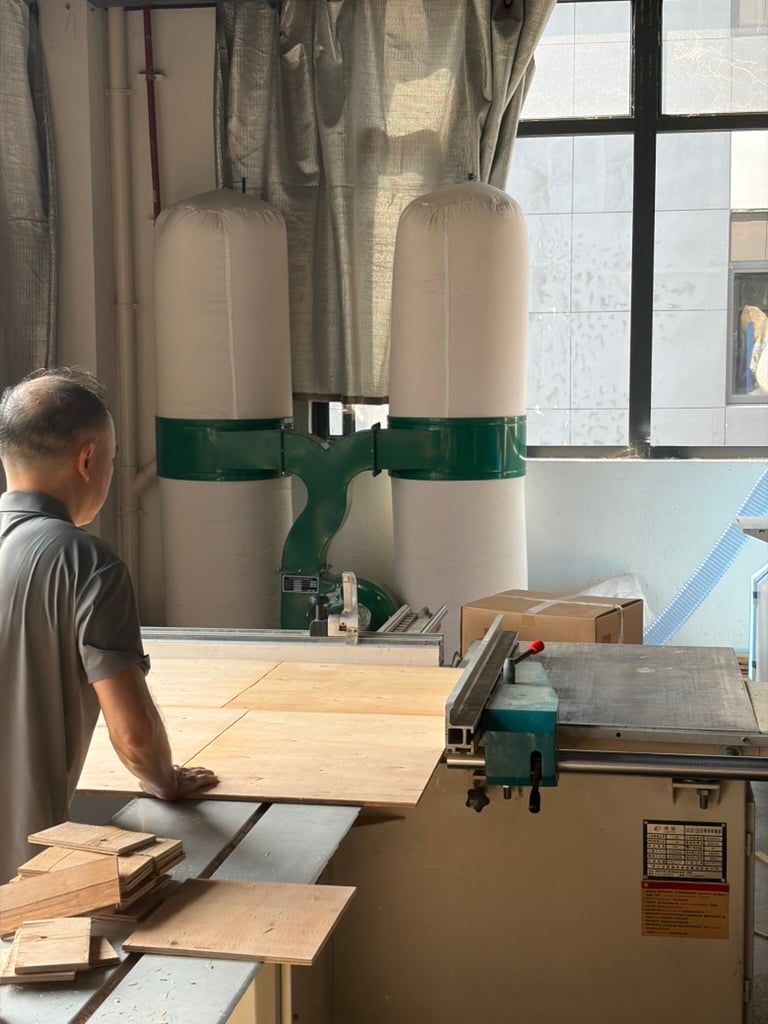
2026/10/09
Explore PackCube’s custom plywood pallet project, from design and prototypes to customer on-site validation, mass production after approval, and shipment.
2026/10/06
Compare equipment packaging proposals using the same configuration, shipment conditions, evidence, acceptance criteria and cost scope, without assuming a material winner.
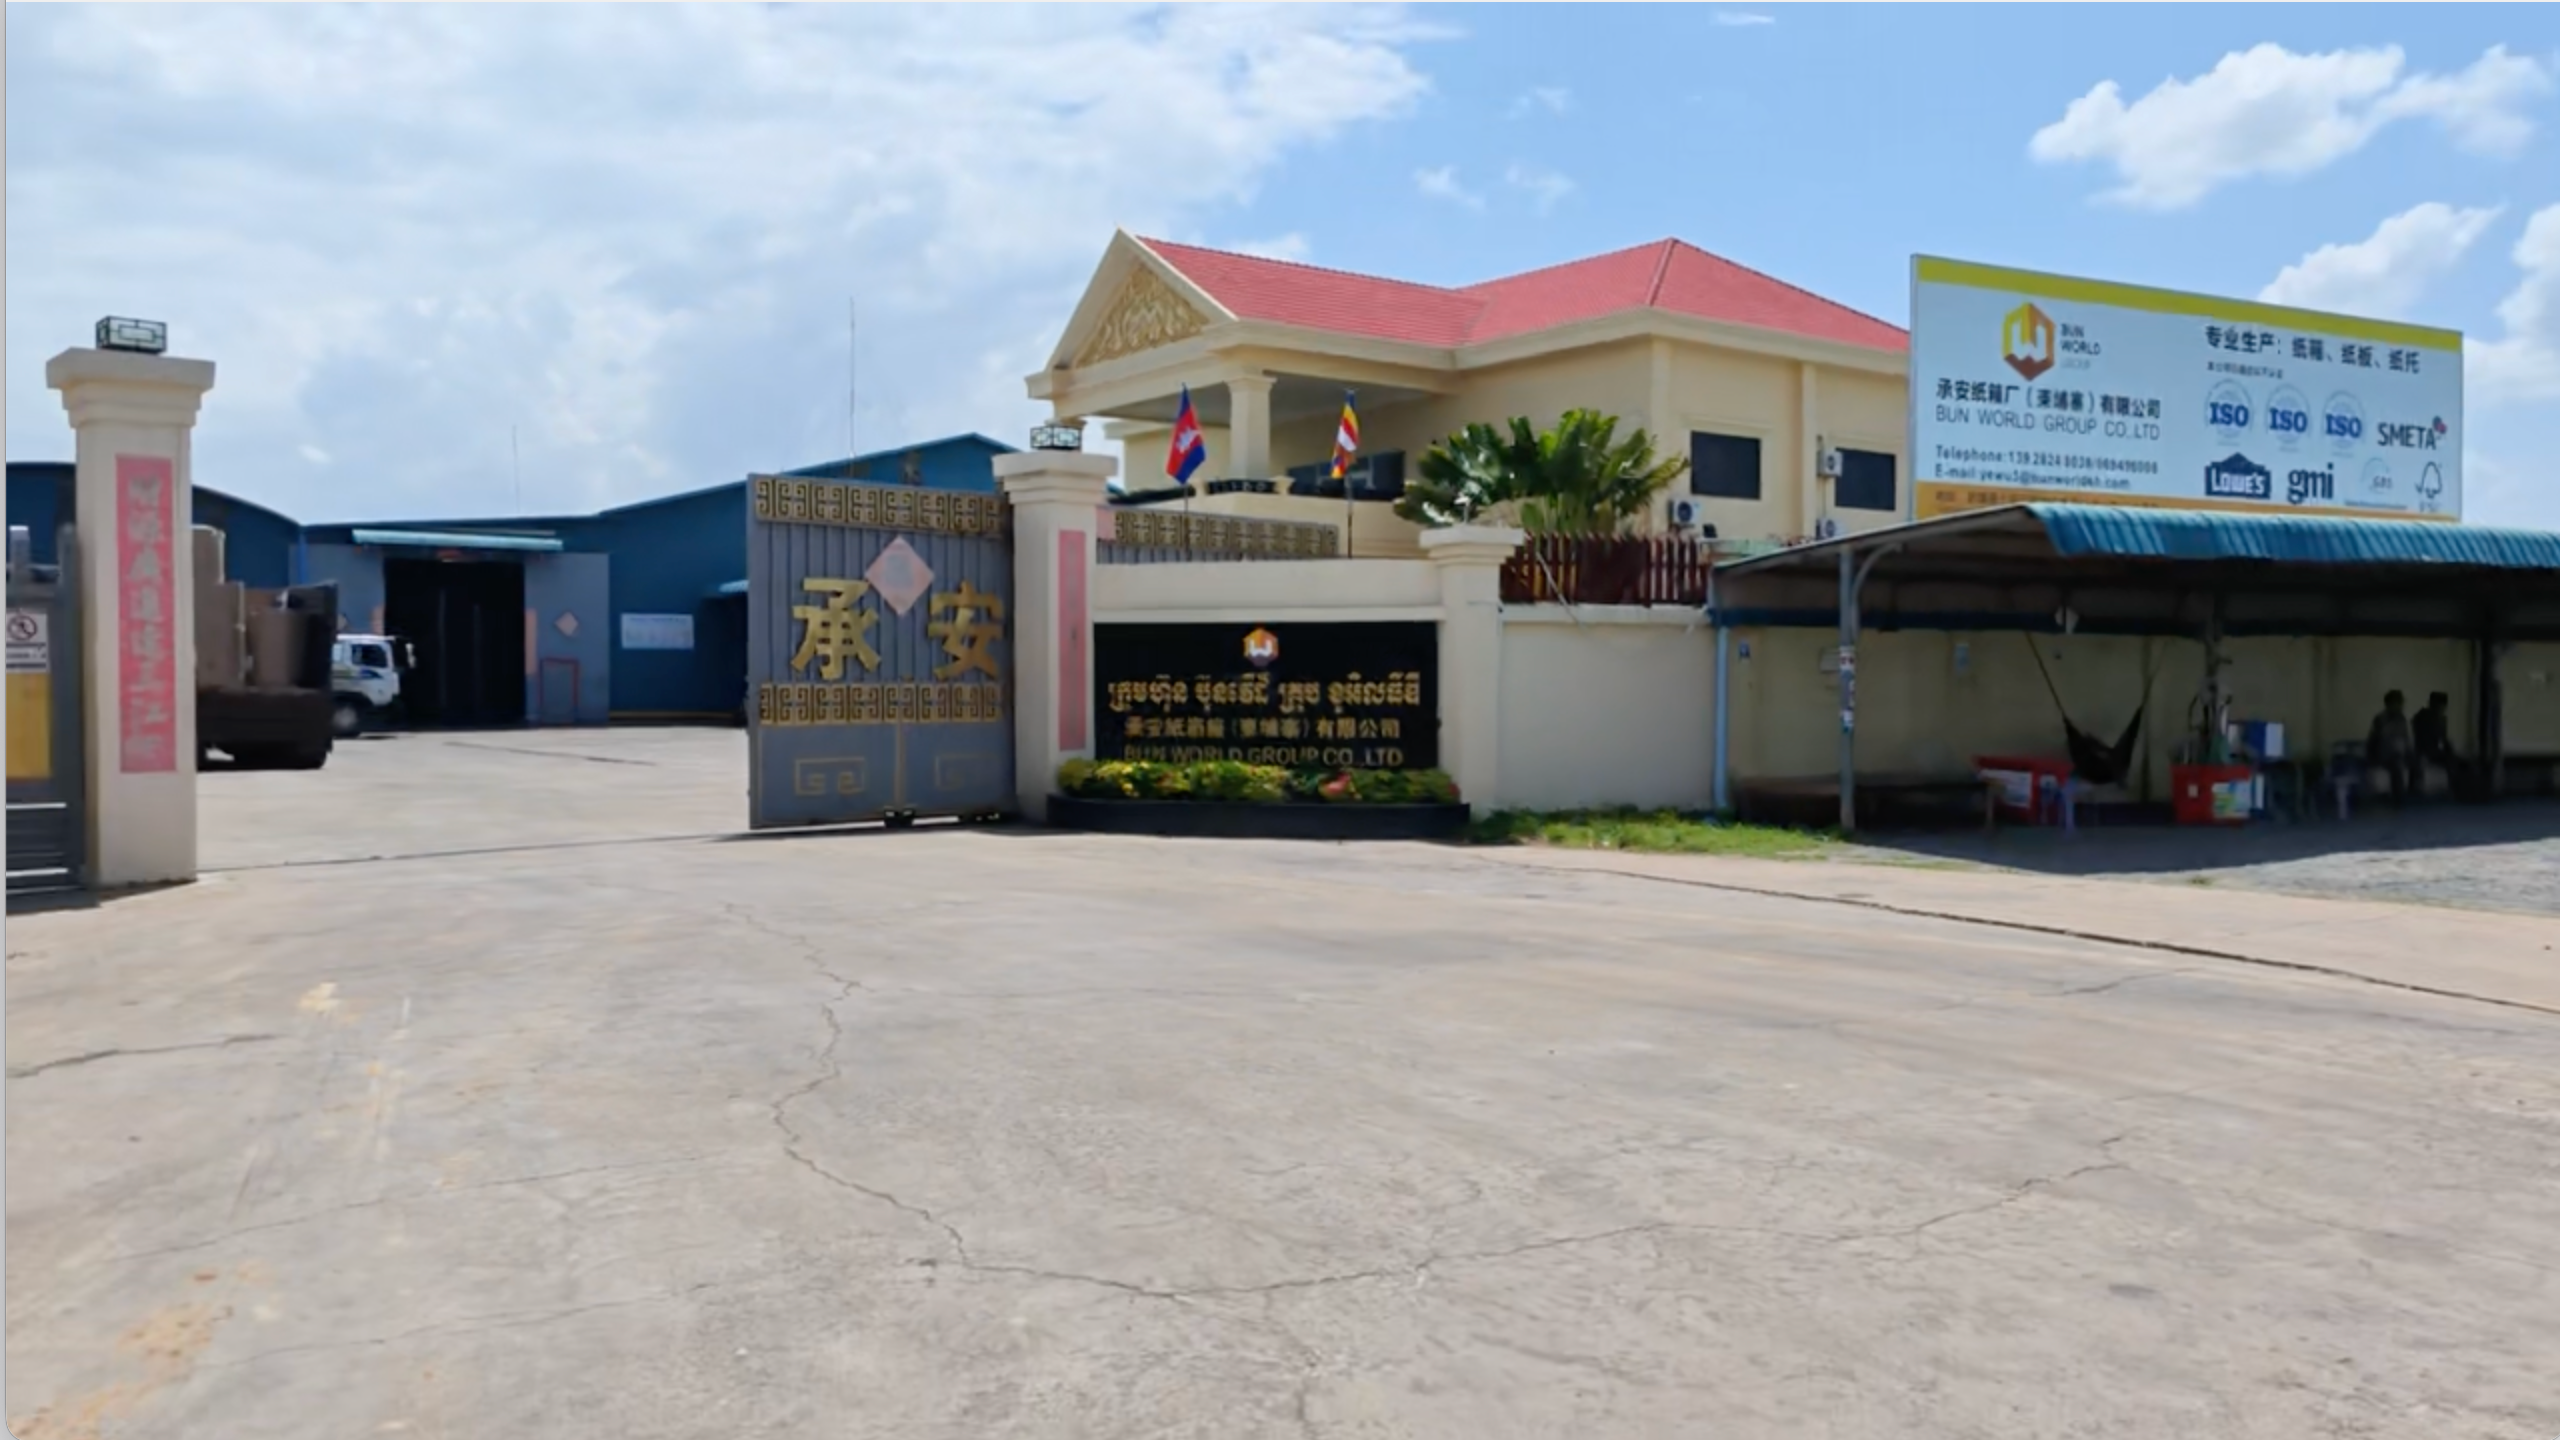
2026/10/04
Explore our Cambodia molded pulp packaging operation through factory and workshop photos showing forming equipment, drying racks and production handling.
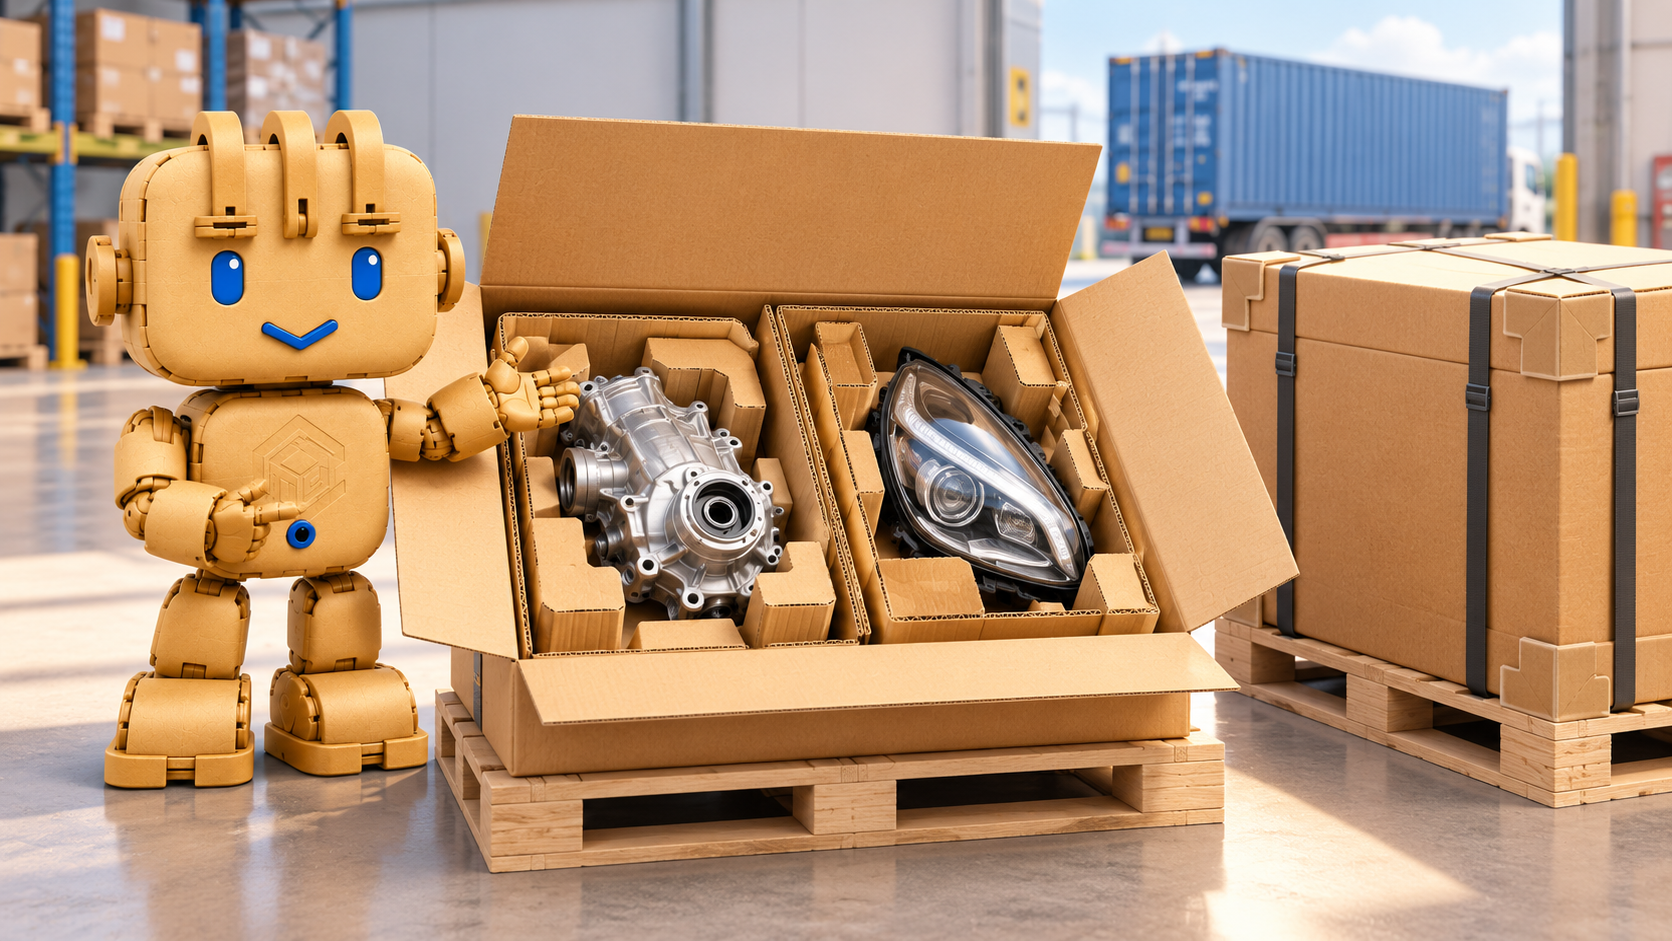
2026/10/03
Explore six key checks for automotive parts export packaging, including product protection, moisture control, pallet stability, compliance and validation.
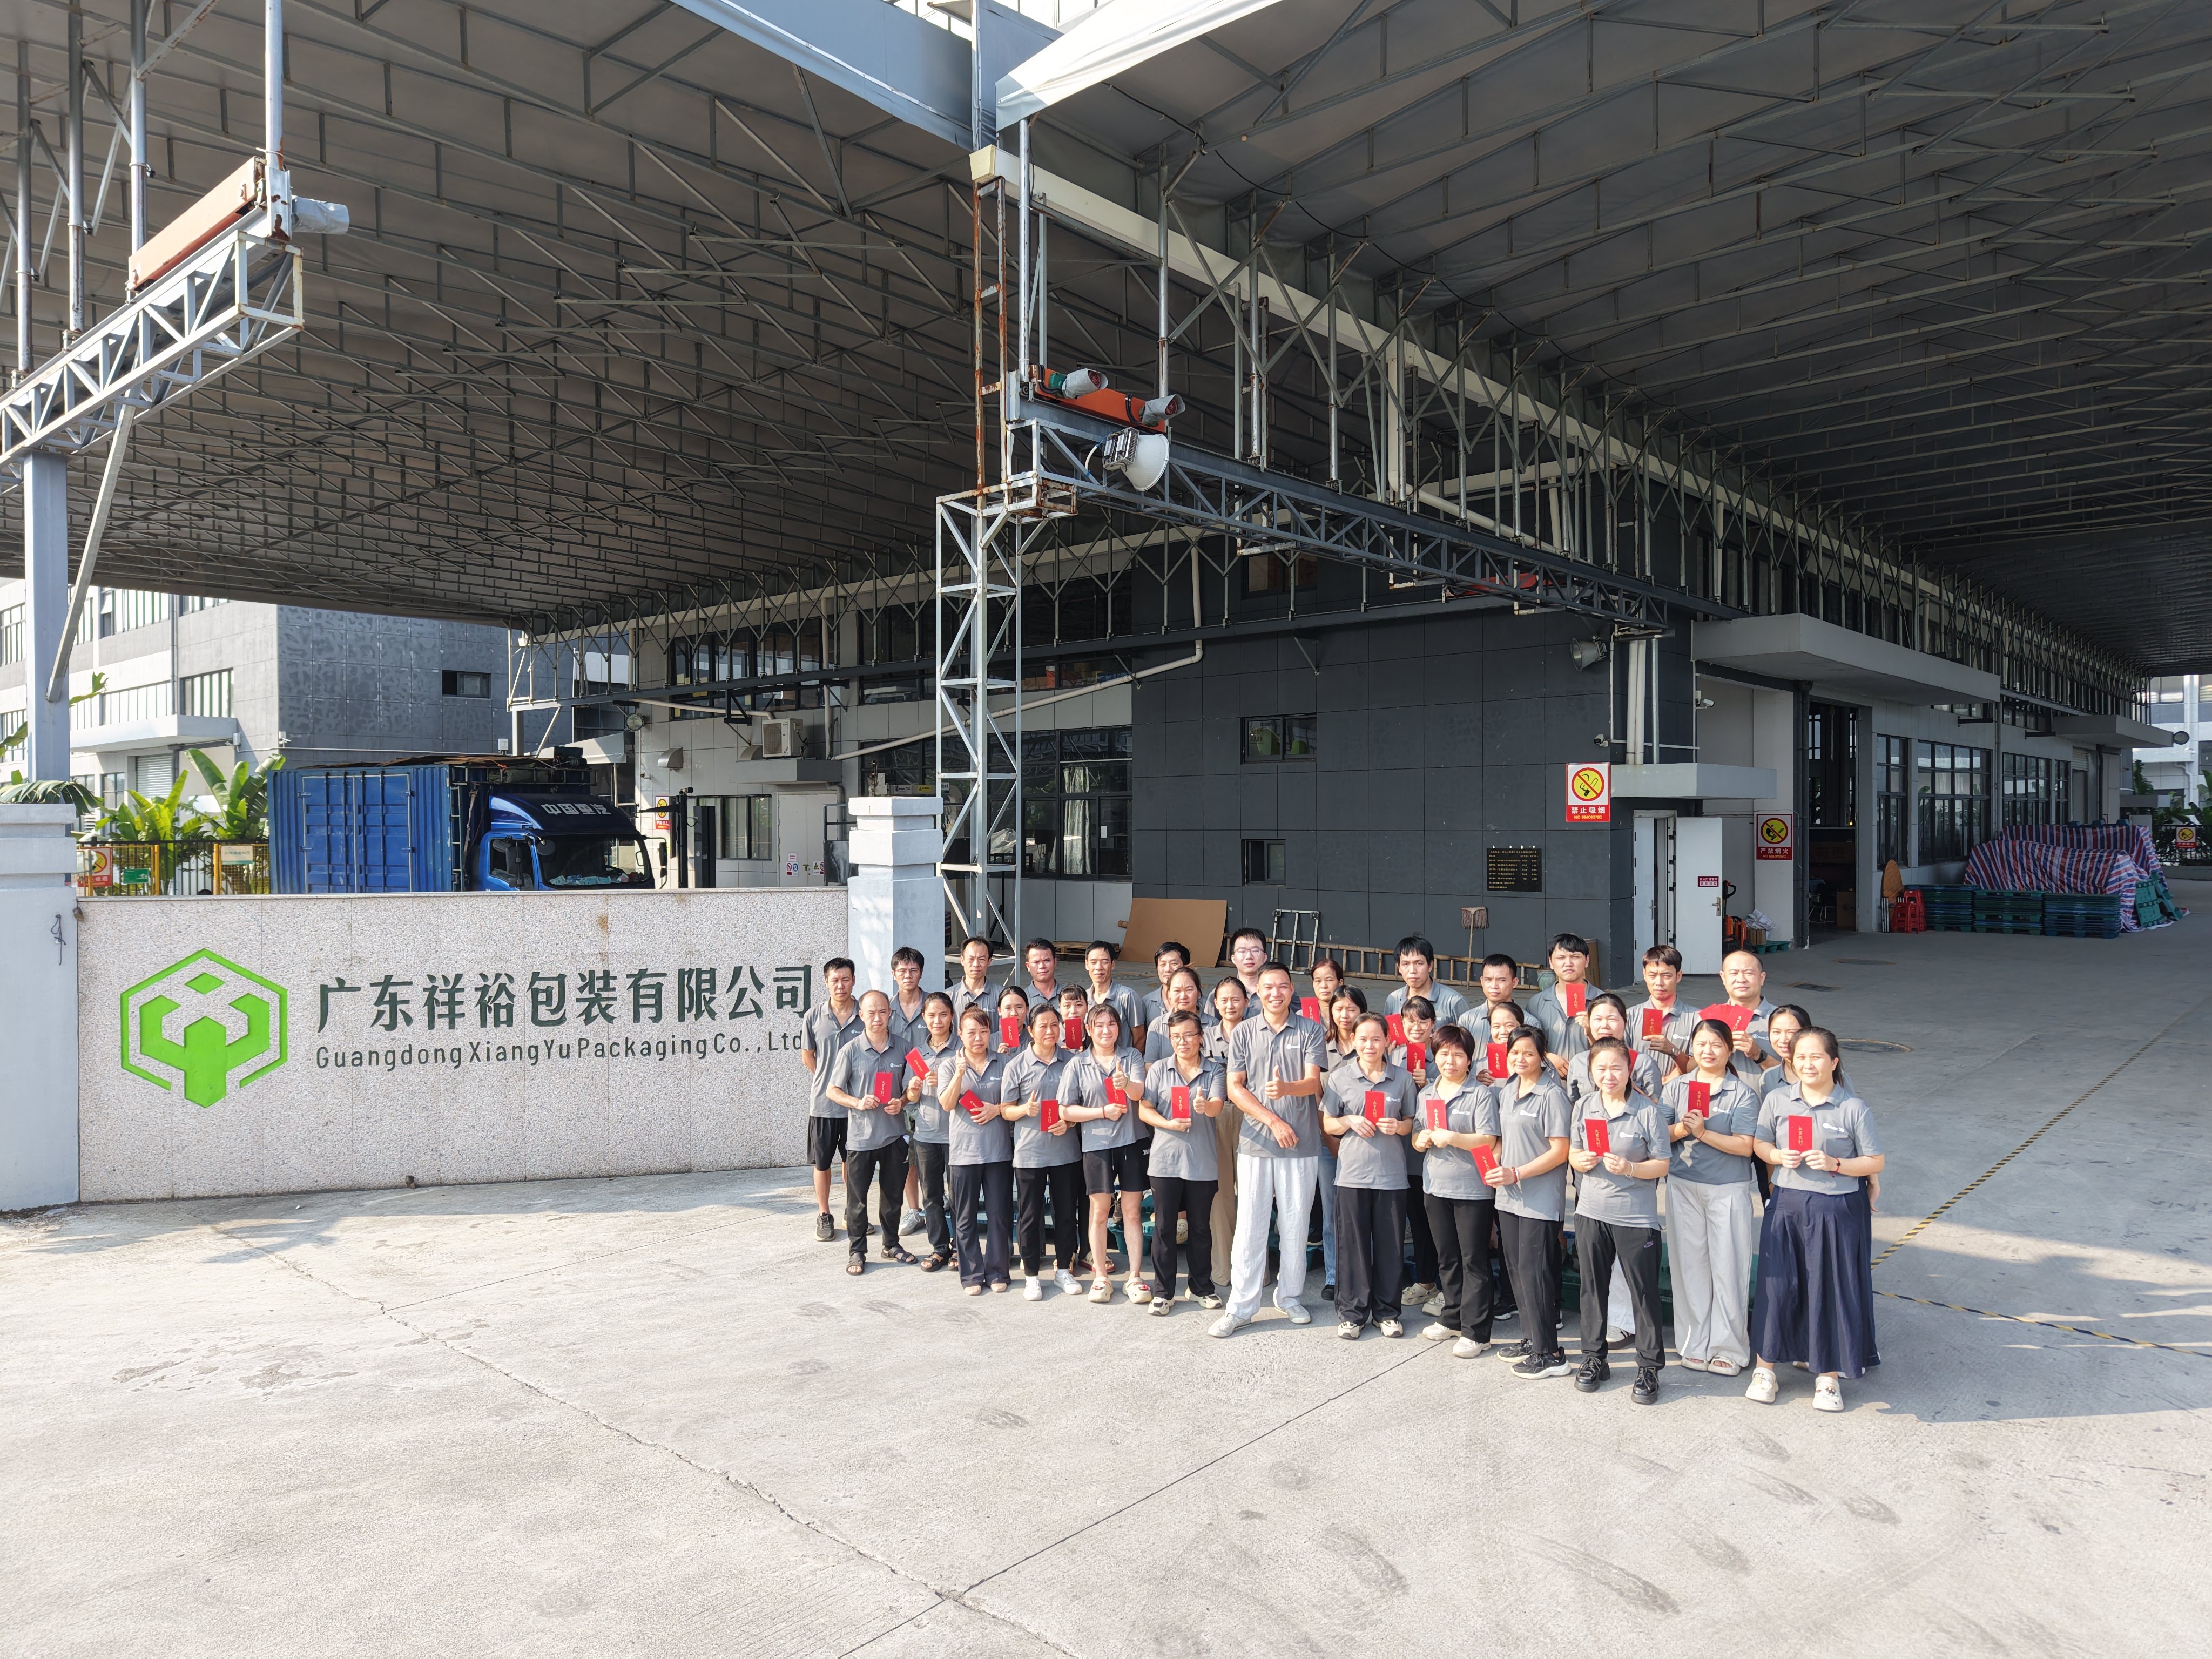
2026/10/02
Guangdong Xiangyu Packaging celebrates the Mid-Autumn Festival with a team photo and festive meal, sharing seasonal joy and strengthening team connections.
2026/09/30
Prepare product, measurement, route, handling, protection and quantity information before an industrial packaging design discussion.